Composition
Lecture 9A. See csse1001 for course logistics and python-composition for the full reference on has-a relationships.
Outline
- The DRY principle, and two ways to reuse classes: composition and inheritance
- Composition (“has-a” relationships)
- Worked example:
DroneFlightcomposed ofBattery,Camera, andMotor - Hot-swapping composed objects
Recap
Dunder methods from last lecture (see 2025-09-16-dunder-methods, python-dunder-methods):
| Category | Key methods | What they enable |
|---|---|---|
| Lifecycle | __init__ |
Control object initialisation |
| String rep | __repr__, __str__ |
Unambiguous & user-friendly text |
| Numeric ops | __add__, __sub__, __mul__, … |
Custom arithmetic (1/2 + 1/3, v1 * v2) |
| Comparisons | __eq__, __lt__, __gt__, … |
Sorting, ==, < |
And representation invariants (see 2025-09-16-representation-invariants, python-representation-invariants):
| What? | Why? | How? |
|---|---|---|
| Conditions that must hold for an object’s private state at all times (e.g. \(0 \leq \text{altitude} \leq 120\), ID is 6 digits). | Prevents invalid states; simplifies reasoning & testing (assume invariants true); catches bugs early with clear, localised checks. | Set valid values in __init__; centralise assertions in a private helper like _check_invariants(). |
Reusing code
DRY (don’t repeat yourself) principle: in general, duplication and copy/paste are bad:
- Increased risk of bugs.
- Maintenance overhead.
- Poor readability.
- Code bloat.
- Signals that a common abstraction/refactoring is needed.
There are two ways to reuse classes in a new class: composition and inheritance.
Composition
We can use objects built from other classes (implemented by us or others) as attributes of our new class/object. This isn’t new — we’ve already used integers, strings, lists, etc. as attributes for our classes; we can do this with other (more complex) classes as well. For example, if we are implementing a Robot class, we can use an object from a Battery class (already implemented by us or others) as one of its attributes.
Modularity:
- A
Studenthas aString(e.g. to store the student’s name). - A
Robothas aSensor,Motor, etc.
Has-a relationship
When an object (say Car) includes another object inside itself as an attribute (say Engine), this forms a has-a relationship — we call this class composition:
>>> class Car():
...     def __init__(self, engine : Engine) -> None:
...             self._engine = engine        # Car has-a engine.
The relationship is drawn as one box inside another, not as a line between two boxes. The whole encloses the part:
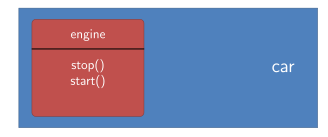
Figure 1: Composition as containment. The steel-blue rectangle is the whole (the car object); the brick-red rounded rectangle nested inside it is the part (the engine object), with its own methods stop() and start() listed under a rule. Nesting is the notation: a has-a relationship is drawn by putting the part inside the whole. A connecting line comes with UML in week 10.
Using it:
engine = Engine()
car = Car(engine)
car.engine.start()
car.engine.stop()
print(car.engine.power)car.engine does not match self._engine
The snippet reaches into the part as car.engine, but the __init__ above stores the part as self._engine, a private attribute. Written literally, car.engine would raise AttributeError.
The snippet is there for the shape of the relationship, not as a runnable transcript. The same mismatch recurs in the hot-swapping example below, where it changes what the code does.
Is-a or has-a
Recall the DroneFlight representation-invariants exercise from last lecture. The brief:
- Drone ID — exactly six alphanumeric characters (e.g.
"A1B2C3"). - Altitude — must stay within 0 m – 120 m, the CASA (Civil Aviation Safety Authority) legal ceiling for recreational drones.
- Battery — an integer percentage in the range 0 – 100.
The recap table above states the ID rule more loosely as “ID is 6 digits”. “Six alphanumeric characters” is the version to work from, since "A1B2C3" is not six digits.
“A Drone has a Camera” reads clearly; “A Drone is a Camera” does not. A drone has a camera, has a motor, and has a battery, so composition is the natural fit here, not inheritance.
Worked example: DroneFlight
class Battery:
    def __init__(self, capacity: int = 100) -> None:
        if capacity < 0:
            raise ValueError("Capacity must be non-negative.")
        self._level = capacity   # percentage

    def use_power(self, amount: int) -> None:
        if amount < 0:
            raise ValueError(f"Power usage must be non-negative.")
        self._level -= amount
        if self._level < 0:  self._level = 0
        print(f"Power used: {amount}%. Remaining: {self._level}%.")

    def get_level(self) -> int:
        """Return remaining battery charge (percentage)."""
        return self._level


class Camera:
    def __init__(self, resolution: str = "12MP") -> None:
        self._resolution = resolution

    def take_photo(self) -> None:
        print(f"Photo taken at {self._resolution} resolution.")


class Motor:
    def __init__(self, power_rating: float = 100.0) -> None:
        self._power_rating = power_rating   # Watts
        self._is_running = False

    def start(self) -> None:
        self._is_running = True
        print("Motor started.")

    def stop(self) -> None:
        self._is_running = False
        print("Motor stopped.")
Each of the three is a complete, self-contained class that knows nothing about drones. DroneFlight then holds one of each:
class DroneFlight:
    _ID_LEN = 6
    _MAX_ALT = 120.0   # metres (CASA limit)

    def __init__(self, flight_id: str, battery: Battery,
                 camera: Camera, motor: Motor) -> None:
        self._id = flight_id
        self._altitude = 0.0
        self._battery = battery   # Drone has-a Battery
        self._camera = camera     # Drone has-a Camera
        self._motor = motor       # Drone has-a Motor
        self._check_invariants()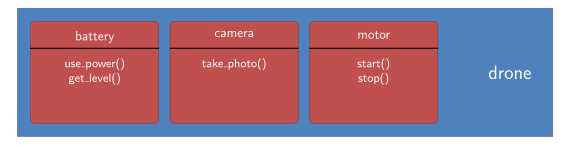
Figure 2: The DroneFlight object: one whole holding three parts, each part a complete class in its own right. The battery, camera and motor boxes are nested inside the drone box, the same containment notation as car and engine, and each part lists its own methods under a rule.
The rest of DroneFlight is written entirely in terms of those three parts. It never touches their internals, only their public methods:
    def get_flight_id(self) -> str:
        """Return the immutable flight identifier."""
        return self._id

    def get_altitude(self) -> float:
        """Return current altitude in metres."""
        return self._altitude

    def get_battery(self) -> int:
        """Return remaining battery charge (percentage)."""
        return self._battery.get_level()

    def __str__(self) -> str:
        return (f"DroneFlight({self._id}, alt={self._altitude:.1f} m, "
                f"bat={self.get_battery()}%)")

    def ascend(self, metres: float) -> None:
        """Climb *metres* metres (cannot exceed the legal ceiling)."""
        if metres < 0:
            raise ValueError(f"ascend() expects a positive distance.")
        self.set_altitude(min(self._altitude + metres, self._MAX_ALT))
        self._check_invariants()

    def land(self) -> None:
        """Land the drone and consume 5% battery."""
        self.set_altitude(0.0)
        self._battery.use_power(5)
        if self._motor.is_running():
            self._motor.stop()
        self._check_invariants()

    def take_photo(self) -> None:
        if self._battery.get_level() < 5:
            print("Not enough battery to take photo.")
            return
        self._camera.take_photo()
        self._battery.use_power(5)
get_battery() delegates straight to self._battery.get_level(). Don’t call use_power(0) here. Just show the level. Even a zero-amount power use would print a spurious Power used: 0%. Remaining: ... line and would be conceptually the wrong operation: a getter reports state, it does not perform an action on the part.
Every method above has the same shape: DroneFlight decides when something happens and what the rules are (the 5% battery threshold, the 120 m ceiling), and the part decides how it happens. That division is the whole point of composition. take_photo() is the clearest case: the drone checks the battery, the camera takes the picture, the battery bills for it, and no class knows more than its own job.
Gaps in the listing
The listing above is not self-contained. It has four gaps:
set_altitude()is called but not defined above. Bothascend()andland()go through it rather than assigningself._altitudedirectly, which is the right instinct, because a setter is where an invariant check belongs. Lecture 8B’sDroneFlightdefines one._check_invariants()is called but not defined above either. It is the helper from the previous lecture.Motorhas nois_running()method.land()callsself._motor.is_running(), but theMotorclass above defines only the attributeself._is_runningand the methodsstart()andstop(). As written,land()would raiseAttributeError; the class needs a getter (orland()needs to consultself._motor._is_running, which would reach into a private attribute and defeat the encapsulation the example is demonstrating)._ID_LEN = 6is declared as a class constant but not used in any method above. It belongs to the invariant check, which is not in the listing.
Transcript
>>> b = Battery(); c = Camera (); m = Motor()
>>> d = DroneFlight("SAD564", b, c, m)
>>> d.ascend(80); d.take_photo()
Photo taken at 12 MP resolution.
Power used: 5%. Remaining: 95%
>>> d.land()
Power used: 5%. Remaining: 90%
>>> print(d)
DroneFlight(SAD564, alt=0.0 m, bat=90 %)
This transcript is not exact output. The default resolution is the string "12MP", so the real line reads 12MP resolution. use_power ends its message with a full stop, and __str__ has no space before the %. Read it for the sequence of events, not character by character.
The sequence itself is right: ascend(80) is silent, take_photo() costs 5%, land() costs another 5%, and the final state is 0.0 m and 90%. That holds only once the pieces missing from the listing are supplied. With set_altitude() and _check_invariants() from lecture 8B, which defines both, one gap still bites: land() calls self._battery.use_power(5) before self._motor.is_running(), so it prints its battery line and then raises AttributeError, because Motor has no is_running(). The closing print(d) is not reached in a real session.
Hot-swapping
Because a composed attribute is just a reference to an object, it can in principle be replaced by any other object that supports the operations actually used on it. No shared base class is required. Take a camera that isn’t a Camera:
class ThermalCamera:
    def __init__(self, resolution: str = "12MP"):
        self.resolution = resolution

    def take_photo(self):
        print(f"Thermal image saved.")
>>> b = Battery(); c = Camera (); m = Motor()
>>> d = DroneFlight("SAD564", b, c, m)
>>> d.take_photo()
Photo taken at 12 MP resolution.
Power used: 5%. Remaining: 95%
>>> d.camera = ThermalCamera()
>>> d.take_photo()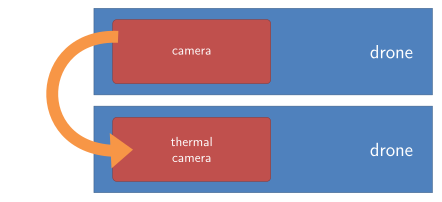
Figure 3: Hot-swapping. The same whole, drawn twice: the part inside it is replaced, and everything around it is untouched. The thick curved orange arrow from the old configuration to the new marks the substitution.
ThermalCamera does not inherit from Camera at all. It just happens to provide a take_photo() method with a compatible signature, so it works as a drop-in replacement. This is duck typing, a standard Python term: Python never checks that the new object is “officially” a Camera, only that it supports the operations actually performed on it. Contrast this with inheritance, where the substitute must be a subclass; see 2025-09-23-inheritance.
d.camera = ... does not actually swap anything
DroneFlight.__init__ stores the camera as self._camera, and take_photo() calls self._camera.take_photo(). Assigning d.camera = ThermalCamera() creates a brand new public attribute called camera and leaves _camera — the one the class actually uses — pointing at the original Camera. The final d.take_photo() above would print Photo taken at 12MP resolution. again, not Thermal image saved.
The idea is sound; the line as written misses the underscore. A working swap needs d._camera = ThermalCamera() (reaching into private state from outside, which the course discourages) or, better, a small setter on DroneFlight that does it deliberately.
python-composition spells out that better version for the Car/Engine pair: a dedicated swap_engine() method that stops the currently-running engine before replacing it. A method gets the chance to clean up the object it is discarding; a bare attribute assignment does not.
Summary
Build by pieces: snap self-contained objects together to create a richer whole.
- Modular: each component handles one clear task.
- Reusable: same parts work in new contexts; no code rewrite.
- Readable: data flow is explicit and easy to trace.
- Few side effects: isolated state keeps surprises and bugs low.
Next: 2025-09-23-inheritance (Lecture 9B), the other way of reusing a class.